Flight-control platforms
Core and Mach form a tiered hardware family for different integration envelopes and operating conditions.
Explore products →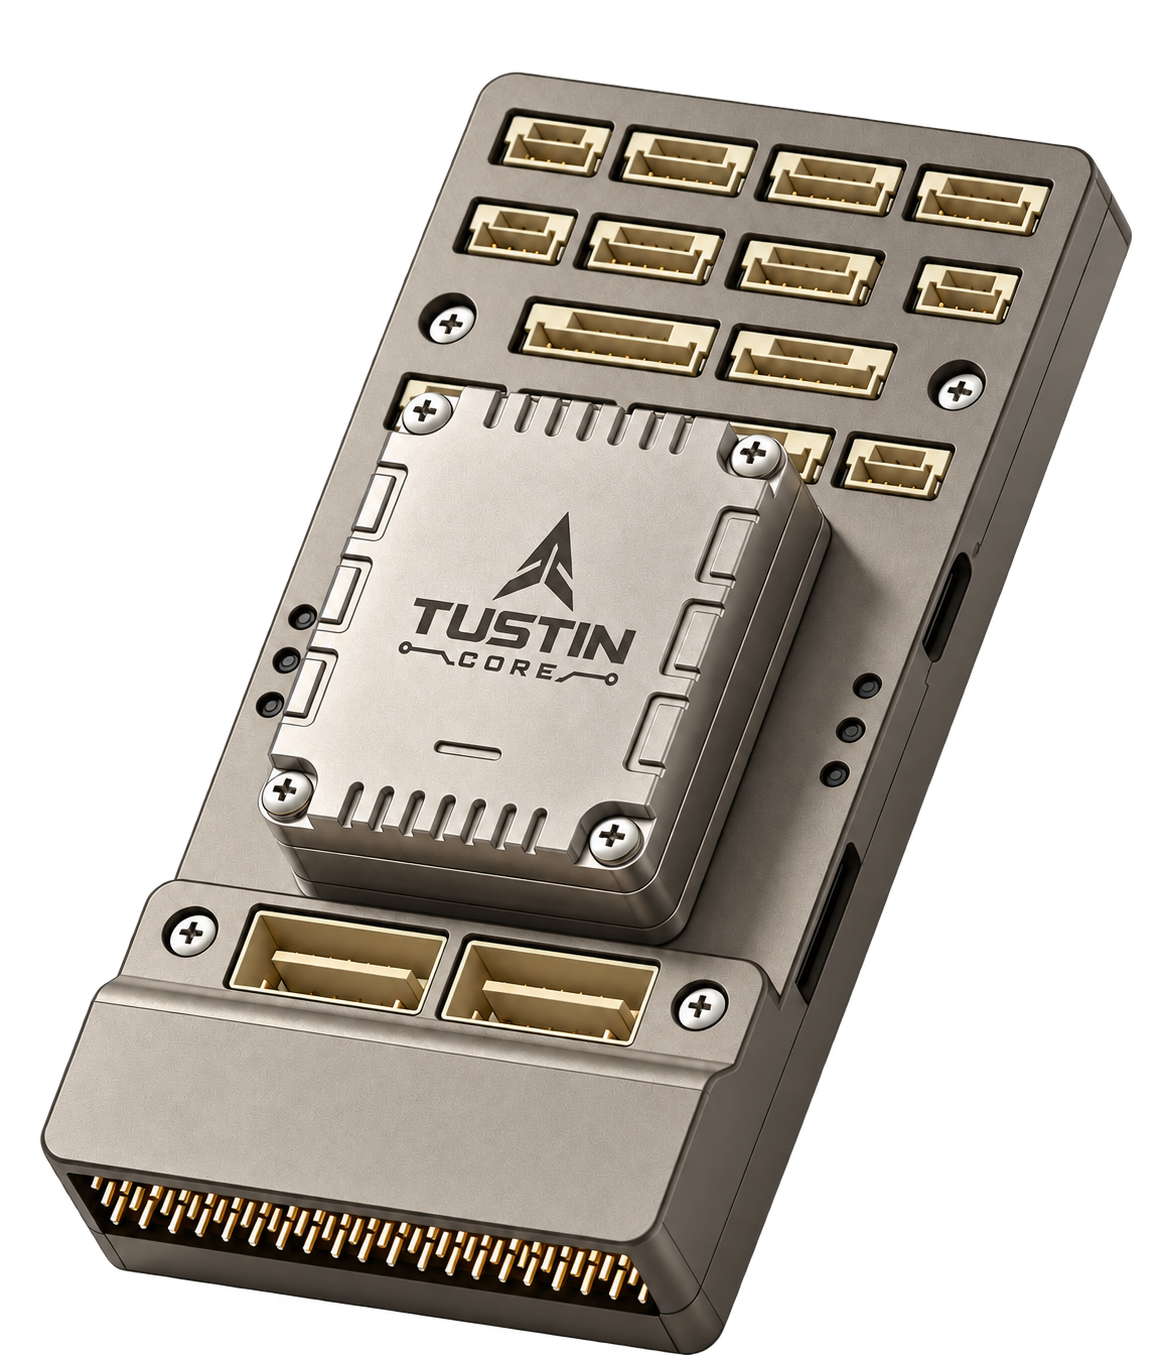
Flight control for aircraft makers and industry applications.
From controller hardware and PX4 / ArduPilot integration to aircraft testing, we support the path from prototype to deployable flight system.
Flight-control hardware, autopilot software and aircraft validation brought together for aircraft manufacturers and industry applications.
Core and Mach form a tiered hardware family for different integration envelopes and operating conditions.
Explore products →Board support, drivers, protocols, parameters and ground-station integration across PX4, ArduPilot and MAVLink.
View engineering capabilities →Modeling, simulation, hardware and software integration, and flight testing connect design to measured performance.
See flight cases →Match flight-control platforms and peripheral interfaces to the aircraft and mission workflow, then validate the integrated system.
Discuss your project →Tustin Dynamics is built by a master's-and-doctoral team with global perspective, elite academic training and deep engineering expertise. Our core members come from Nanjing University of Aeronautics and Astronautics, Beihang University, Northwestern Polytechnical University and EPFL. Every team member was educated at a Project 211 university or an equivalent top-tier international institution, and our core members bring nearly a decade of experience in aerospace engineering and flight-control system development.
Shared purpose makes no distance too great.
We work across the complete autonomous-flight technology stack, from flight-control electronics and embedded autopilots to control algorithms and system integration. We turn advanced research into testable, deployable and production-ready solutions for multicopters, fixed-wing aircraft, VTOL platforms and compact helicopters.
We do more than build products: we help shape the global open-source flight ecosystem. As contributors to ArduPilot, PX4, NuttX, QGroundControl and MAVLink, our work spans flight software, embedded systems and technical standards. Our team drove the complete integration of China's new national UAV Remote ID standard into MAVLink, while Tustin Mach has entered both the ArduPilot and PX4 communities; Betaflight is supported, with INAV support planned, demonstrating our ability to carry technology from standards and software through to flight-ready hardware.
From board-level hardware to flight validation, we build the complete technology chain required to turn advanced flight-control research into dependable, production-ready aircraft systems.
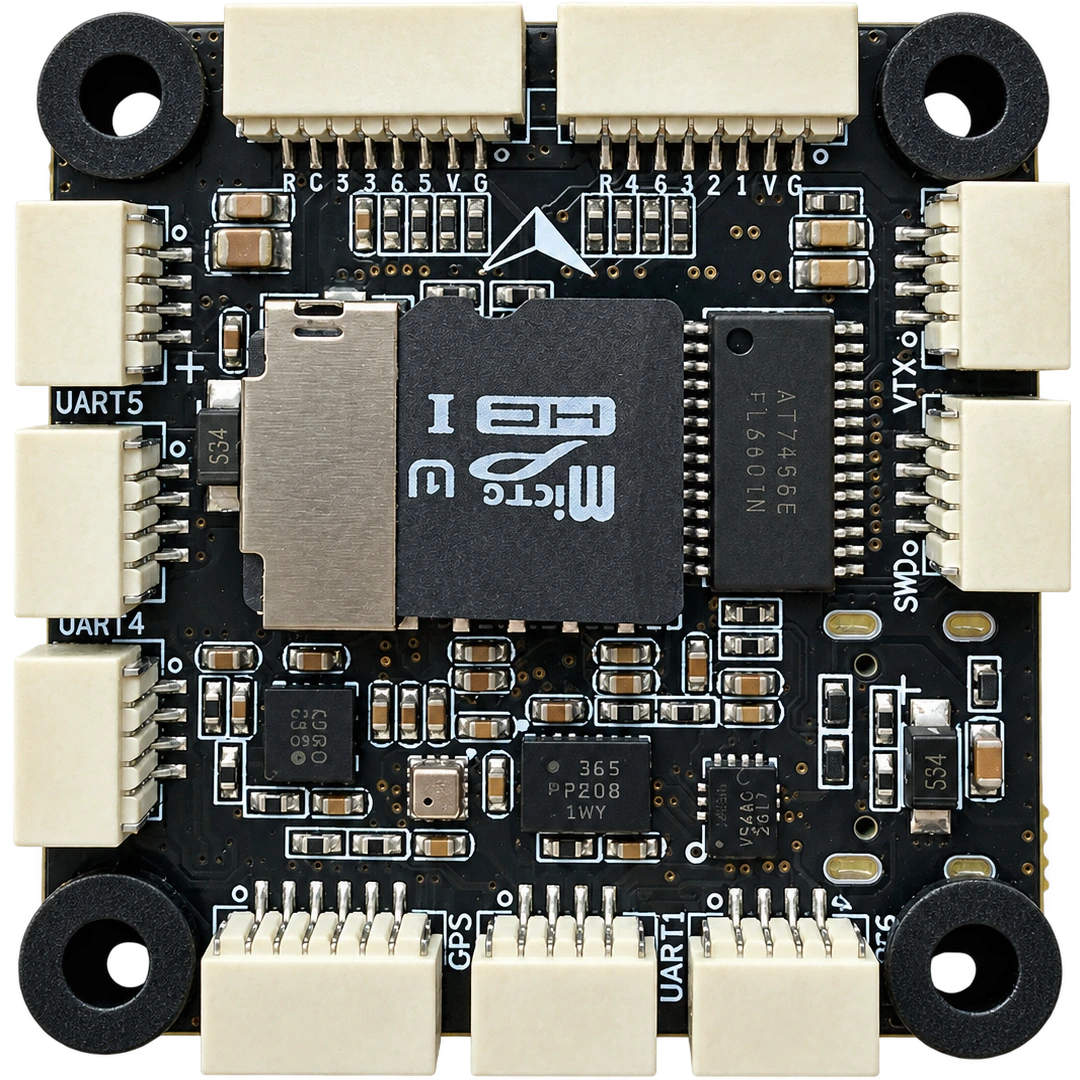
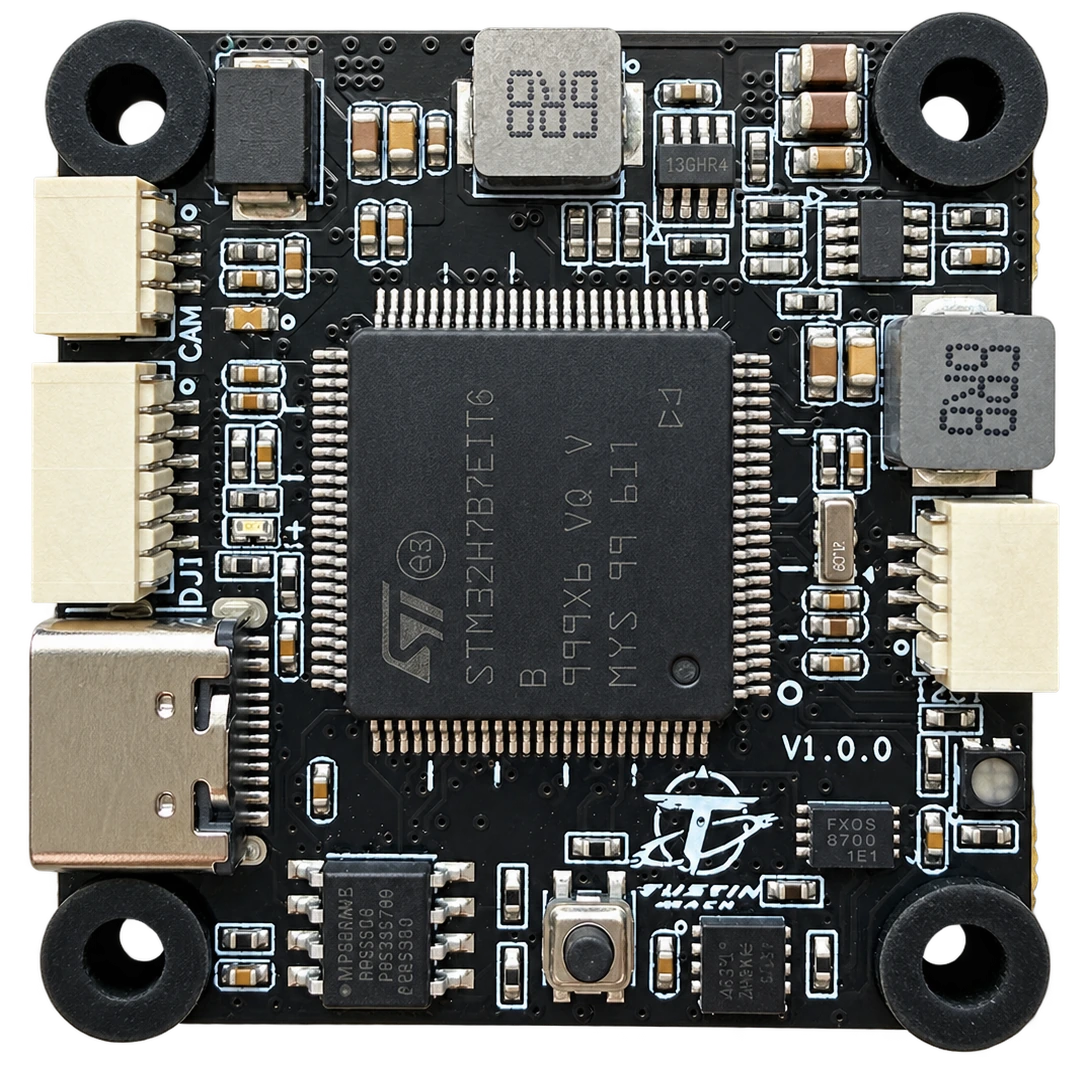
System-level flight-controller design combining high-performance computing, redundant sensing, reliable onboard storage, robust power architecture and protected interfaces for high-speed, high-vibration and space-constrained aircraft.
Deep expertise across PX4, ArduPilot, NuttX and MAVLink, spanning board support, device drivers, communication protocols, parameter systems, ground-station integration and flight validation.
Control solutions for strong disturbances, model uncertainty and actuator faults, including robust control, MPC, INDI, SO(3) geometric control, ADRC, system identification and fault-tolerant control, carried through to real-time deployment.
End-to-end system engineering for multicopters, fixed-wing aircraft, VTOL platforms and compact helicopters, covering modeling, simulation, hardware-software integration, flight testing and iterative performance validation.
Flight-control systems, ground software and complete aircraft platforms engineered for compact, high-speed and autonomous missions.
A tiered flight-control family for research prototypes, engineering integration and demanding autonomous aircraft.
A professional V6X-architecture flight controller for demanding unmanned aircraft and advanced autonomous systems, combining a scalable professional architecture with a complete suite of engineering capabilities for demanding operating conditions. Supports PX4 and ArduPilot.
Tustin Mini is not receiving a routine revision. The product line is being comprehensively rebuilt across form, capability and integration for a new generation of compact platforms. Details will be revealed when the time is right.
An ultra-compact open flight controller for space- and weight-constrained platforms, with CAN expansion and high-rate flight logging for small UAVs, robotics and research prototype integration. Tustin Mach has entered both the ArduPilot and PX4 communities. Betaflight is supported; INAV support is planned.
High-current propulsion electronics developed for compact, high-performance multirotor power systems.
A 3–6S AM32 electronic speed controller rated up to 60 A per channel.


Integrated flight platforms that turn control algorithms, avionics and perception into validated mission capability.
A tail-sitter VTOL platform designed for flight speeds up to 85 m/s and vision-guided autonomy.
View details →A 250–330 mm wheelbase quadrotor platform focused on resilient control and continued stable flight.
A quadrotor platform using vision or LiDAR positioning for autonomous operation.
Ground tools for aircraft configuration, monitoring and efficient flight operations.
An open-source ground control station customized from QGroundControl, with enhanced Chinese localization, flight status and parameter tools.
Real-aircraft footage and flight-validation records from platforms using Tustin flight controllers.
Peregrine I flies with a Tustin Mach controller and an in-house ArduPilot firmware build, demonstrating vertical takeoff, stable flight, target interception and controlled landing.
Browse flight cases →A rapid-launch, high-speed tracking and target-interception demonstration covering guidance-link operation, closed-loop tracking and rapid closure at flight speeds up to 85 m/s.
Browse flight cases →The flight-controller portfolio will continue to expand around Mach, the reimagined Mini line and the continuously evolving Core family, including Core, Core+, Core Pro and future derivatives. Specialized platforms will also address higher-grade sensing, redundancy and additional flight stacks. The concepts below are currently in planning.
Core is designed as a continuously evolving product family. Core+, Core Pro and future variants will extend performance, sensing capability and system integration for different missions.
Flight-controller variants integrating higher-grade inertial sensors for applications with stricter motion-sensing requirements.
A multi-channel redundant flight-control architecture planned for higher fault tolerance and mission continuity.
Planned support for FMT and model-based design (MBD), enabling control engineers to generate deployable code from MATLAB/Simulink models, reduce reliance on low-level hand coding and move algorithms more quickly into hardware validation and flight testing.
We work with customers and partners across universities, research institutions and industry to advance flight control, autonomous systems and unmanned aircraft technologies.
Tustin Dynamics and Huai'an University have signed an agreement to establish an off-campus training base. The partnership brings our end-to-end engineering capabilities in flight-control hardware, embedded systems, autonomous flight and aircraft validation into student internships, hands-on engineering, project-based training and the development of industry-ready technical talent.
Business and technical inquiries:
contact@tustindynamics.com
Phone:
 +1 (940) 616-6622
Phone:
 +8615384253885