Tustin Mach
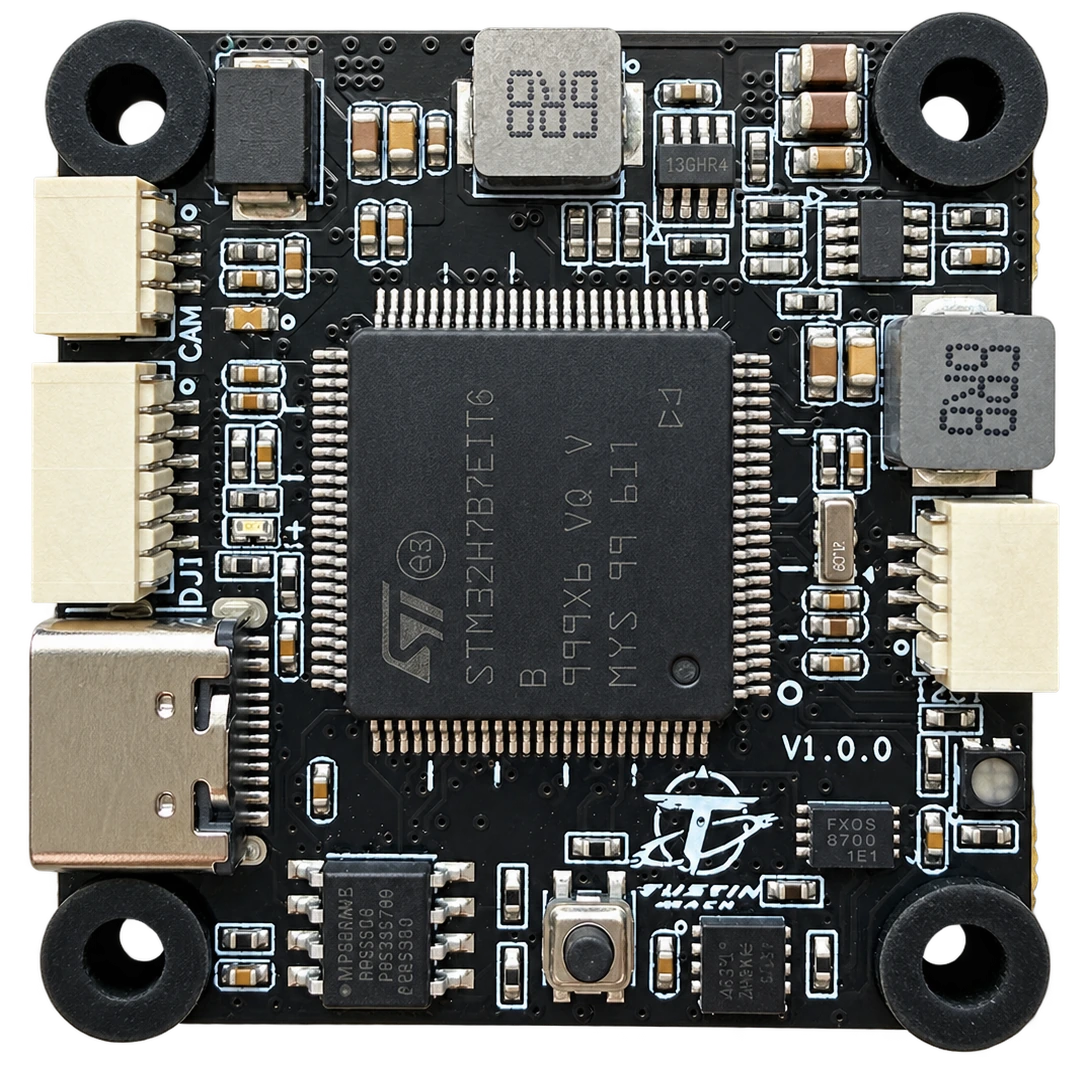
An ultra-compact open flight controller for space- and weight-constrained platforms, with CAN expansion and high-rate flight logging for small UAVs, robotics and research prototype integration. Tustin Mach has entered both the ArduPilot and PX4 communities, with INAV and Betaflight support planned.
Hardware Details
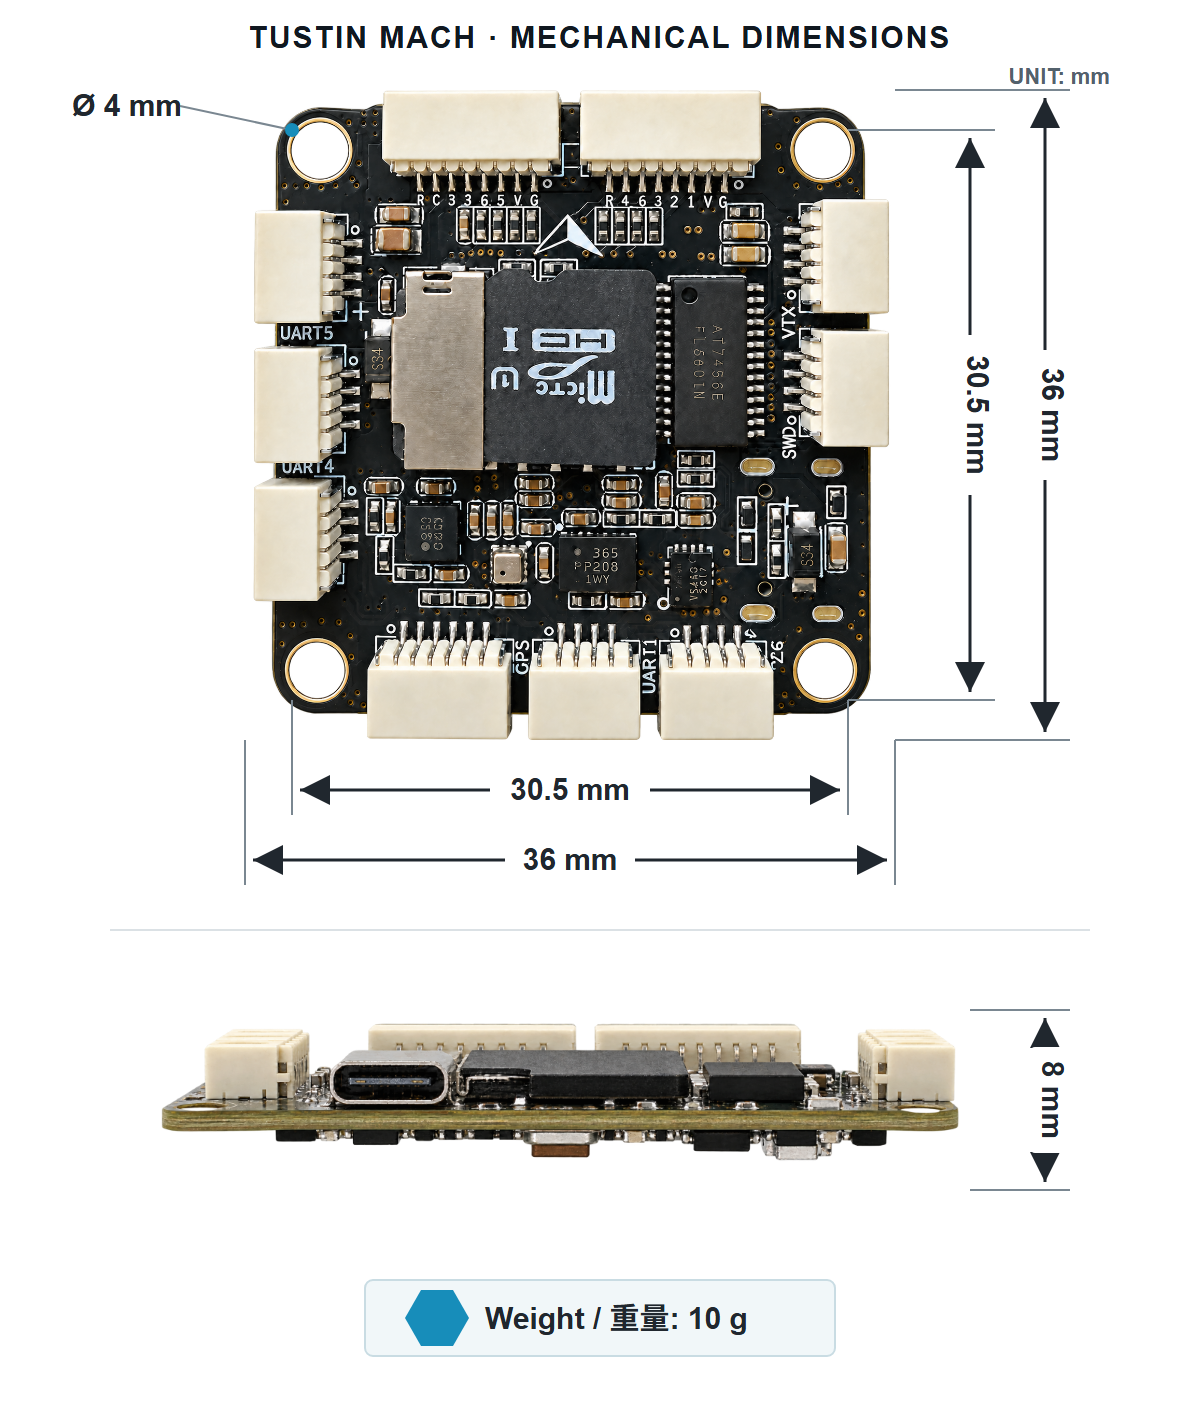
Mechanical Dimensions
36 × 36 mm board, 30.5 × 30.5 mm mounting pattern, Ø4 mm mounting holes, 8 mm overall height and 10 g weight. The side profile is a structural illustration; the physical product takes precedence.
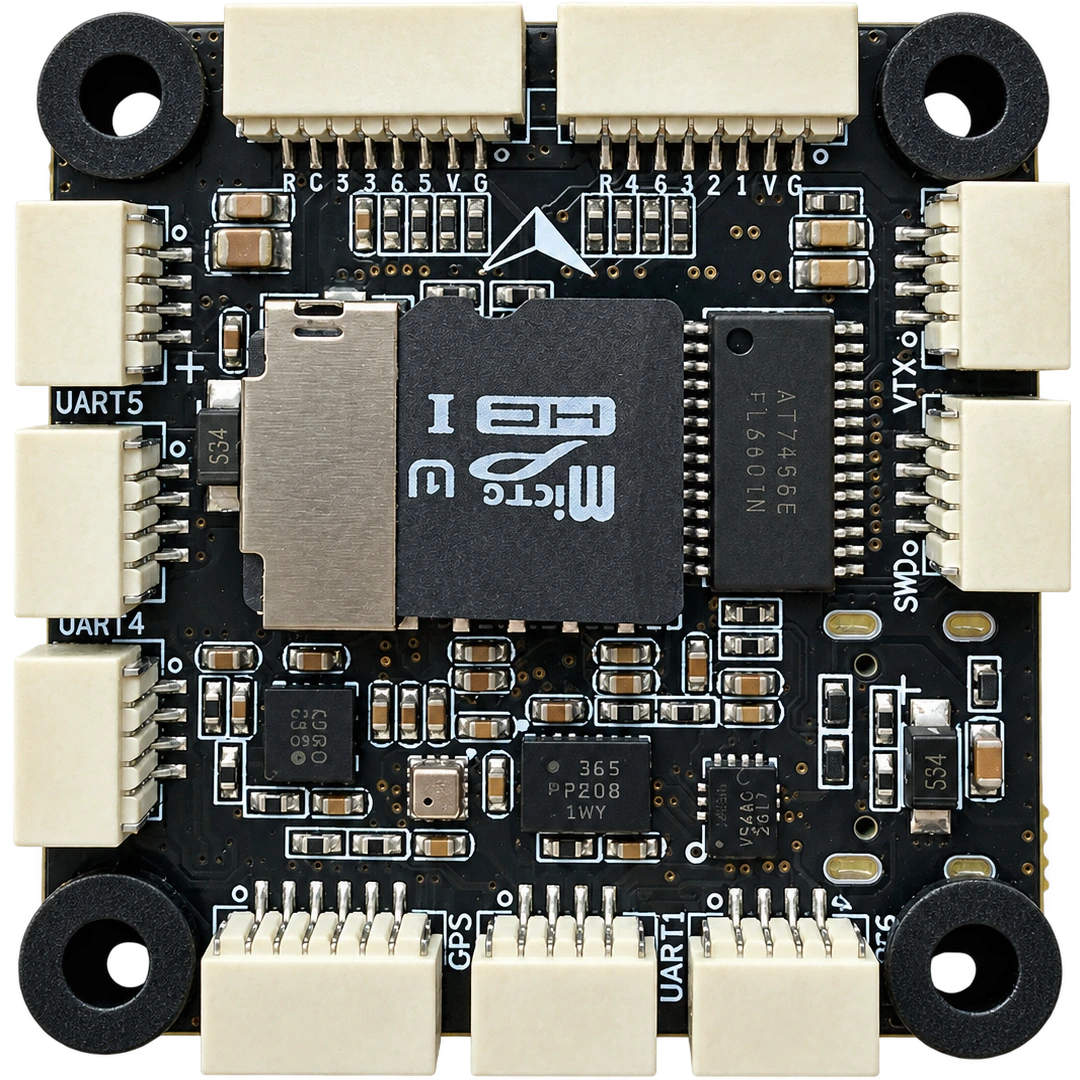
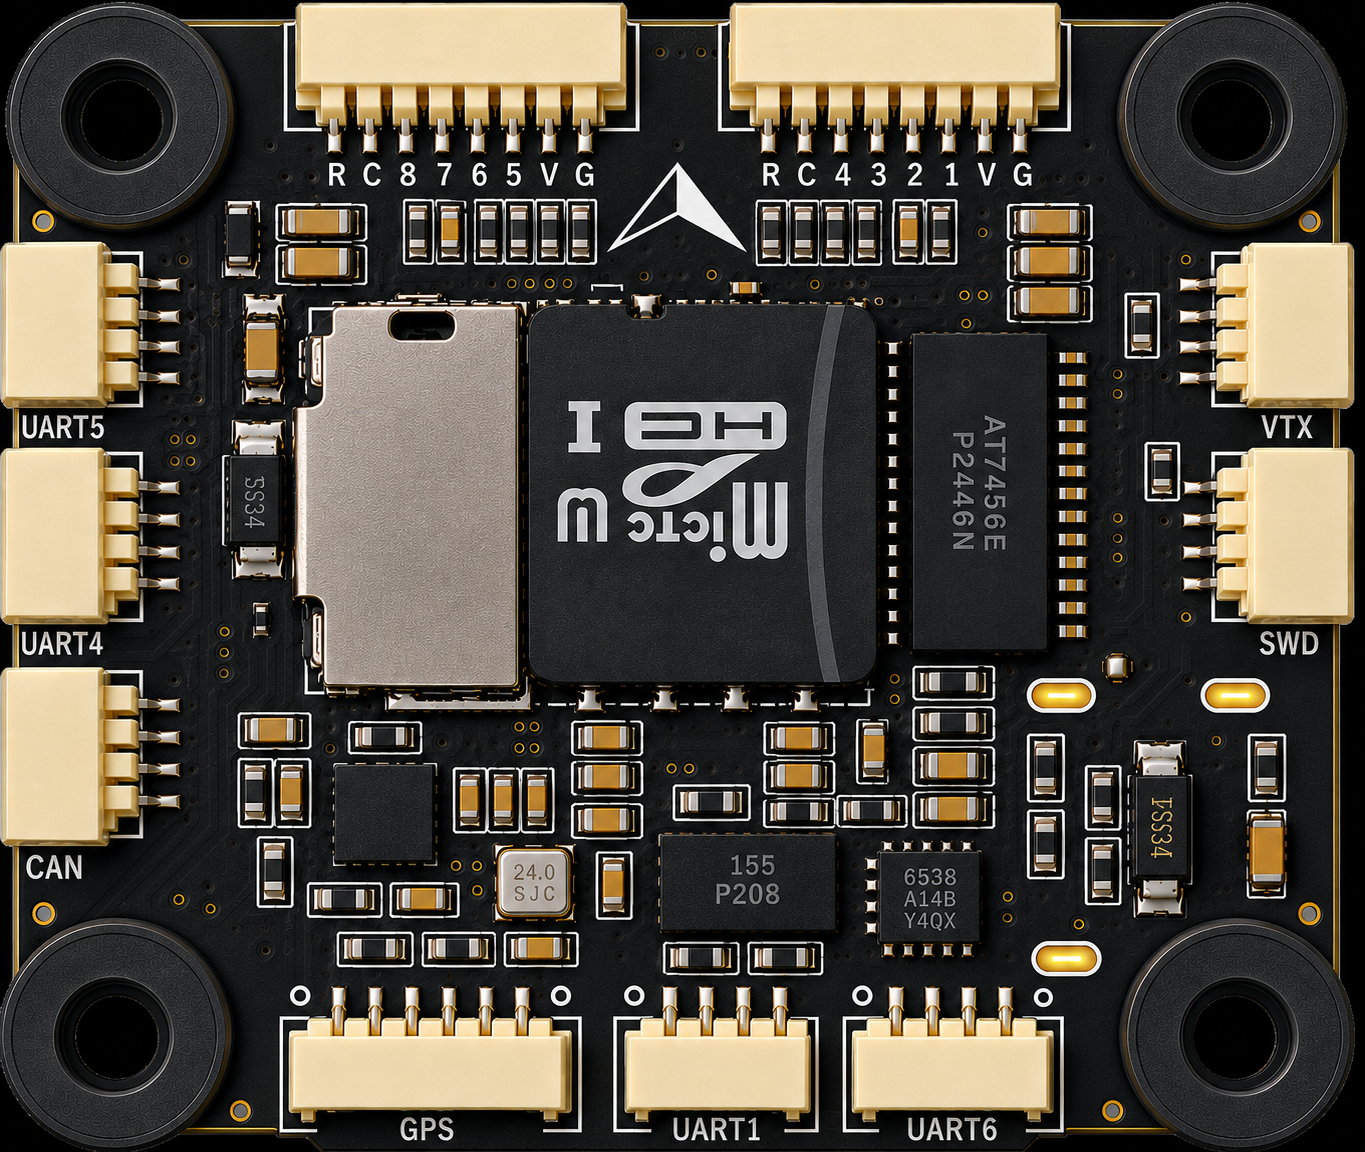
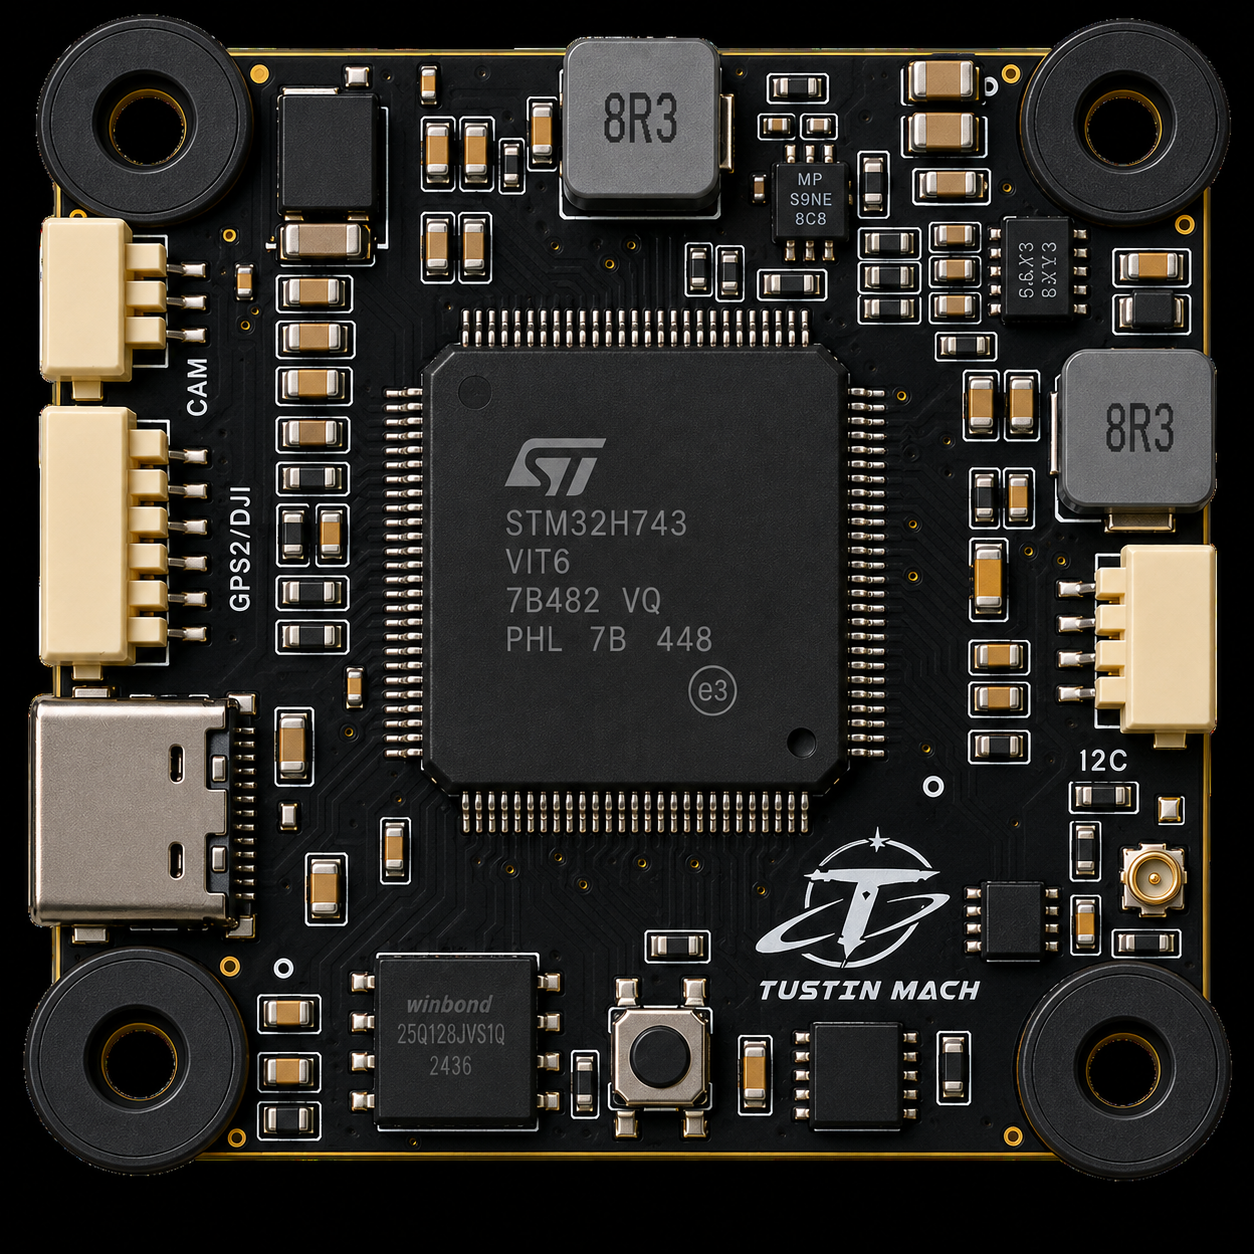
Connector Pinout Diagram
Read horizontal connectors left to right and vertical connectors top to bottom. Board signal connectors use the SH1.0 specification, except for USB Type-C. Product images are provided only to illustrate connector locations and pin order; the physical product takes precedence. Confirm the connector orientation before wiring hardware.
RX7CURM8M7
M6M5VBATGND
RX7CURM4M3
M2M1VBATGND
Both ESC headers share the UART7 receive signal RX7 and current-sense input CUR. VBAT range: 3-8S.
GND5VTX5RX5
GND5VTX4RX4
5VCANHCANLGND
TX2VIDEO_OUTGND12V
SWCLKSWDIOGND3V3
5VTX3RX3SCLSDAGND
GND5VTX1RX1
GND5VTX6RX6
VIDEO_INGND12V
12VGNDTX2
RX2GNDRX6
GNDSDASCL5V
Power connections are not interchangeable: the motor headers carry 3-8S VBAT, the CAM, GPS2/DJI and VTX interfaces use 12V, general peripheral ports use 5V, and SWD exposes 3.3V.
Serial Port Mapping
ArduPilot Serial Port Mapping
| ArduPilot Parameter | Board Port | Physical Layer (Board Silkscreen) |
|---|---|---|
SERIAL0 | USB | USB virtual serial port |
SERIAL1 | TELEM1 | UART1 |
SERIAL2 | GPS2 | DJI |
SERIAL3 | GPS1 | GPS |
SERIAL4 | TELEM2 | UART4 |
SERIAL5 | TELEM3 | UART5 |
SERIAL6 | RC | UART6 |
SERIAL7 | ESC telemetry | UART7 (RX-only) |
- Set each port's function with its corresponding
SERIALx_PROTOCOLparameter. SERIAL7receives ESC telemetry through the sharedRX7signal on both ESC headers.
PX4 Serial Port Mapping
| NuttX Layer | PX4 Layer (Software Parameter Configuration) | Physical Layer (Board Silkscreen) |
|---|---|---|
ttyACM0 | USB | USB virtual serial port |
ttyS0 | TELEM1 | UART1 |
ttyS1 | GPS2 | DJI |
ttyS2 | GPS1 | GPS |
ttyS3 | TELEM2 | UART4 |
ttyS4 | TELEM3 | UART5 |
ttyS5 | RC | UART6 |
ttyS6 | UART6 | UART7 (RX-only) |
ttyS6maps to the receive-only UART7 telemetry signal exposed asRX7on both ESC headers.